Multirotor
, a quadcopter A multirotor or multicopter is a rotorcraft with more than two lift-generating rotors separated horizontally.
≈ 7 min read
Names in other languages
No names in other languages are held for this entry yet.
Article bodies are English and are not machine-translated. A name in another language is not a translation of the article.
A multirotor[1] or multicopter is a rotorcraft with more than two lift-generating rotors separated horizontally. An advantage of multirotor aircraft is the simpler rotor mechanics required for flight control. Unlike single- and double-rotor helicopters which use complex variable pitch rotors whose pitch varies as the blade rotates for flight stability and control, multirotors often use fixed-pitch blades. They control vehicle motion by varying the relative speed of each rotor to change the thrust and torque produced by each. Some control the pitch of each rotor instead.[2]
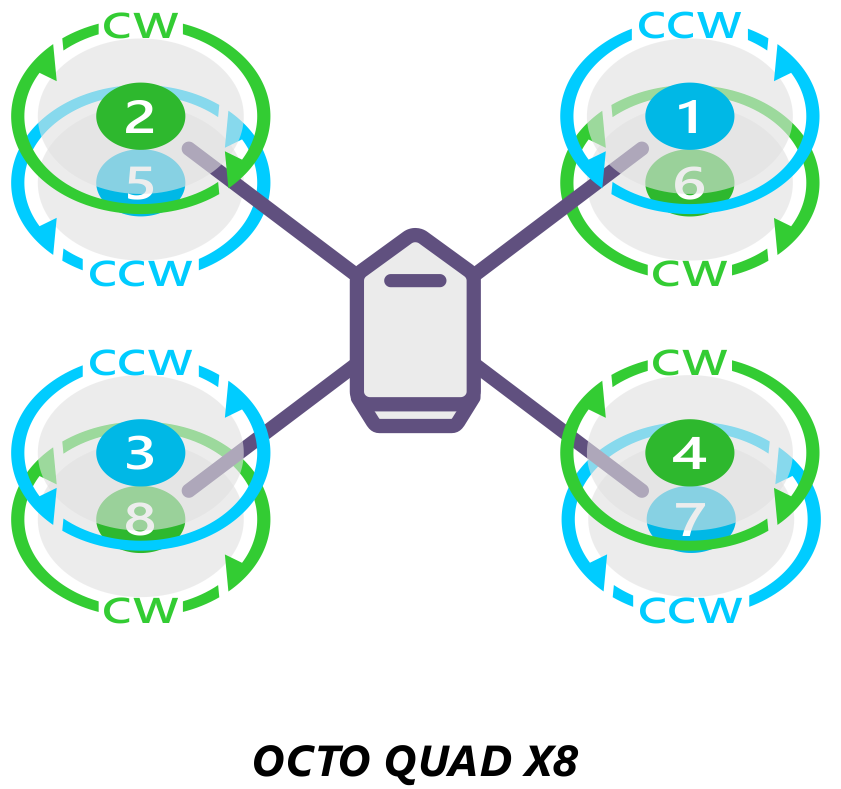
Due to their ease of both construction and control, multirotor aircraft are frequently used in radio control aircraft and unmanned aerial vehicle (UAV) projects[3][4][5][6][7][8] in which the names tricopter, quadcopter, hexacopter and octocopter are frequently used to refer to 3-, 4-, 6- and 8-rotor rotorcraft, respectively.[9] There is also the X8 (also called octo-quad) configuration that is similar to the quadracopter design, except that it has eight rotors; the lower of which have a reversed rotation direction.[10]
In order to allow more power and stability at reduced weight, coaxial rotors can be employed, in which each arm has two motors, running in opposite directions which cancels out rotational torque (one facing up and one facing down).[12]
Also possible is the addition of horizontal propellers.[13][14][15] These types of rotorcraft (which have just 4 vertical propellers) are called quadplanes.[16] It can also be possible by adding additional nonhorizontal wings, which are called lifting-wing multicopters.[17][18][19]
Most multirotors are small, with first-person view and battery power which limits their range, endurance, and payload.[citation needed]
Manned examples
edit edit source- de Bothezat helicopter - an American four-rotor helicopter that first flew on December 18, 1922, and was used for military evaluation.
- Cierva Air Horse - a British three-rotor "heavy lift" helicopter first flying in 1948. Three rotors were used to give a large lift without compromising rotor strength.[20]
- Bensen B-12 - an American experimental ten-rotor personal helicopter first flown on November 2, 1961. The design was later changed to use eight rotors driven by sixteen motors
- "eVTOL" projects:
- Airbus A³ Vahana - two American tiltwing octocopter prototypes. Development was ended in 2019 in favor of the CityAirbus project
- Airbus CityAirbus - a series of experimental multinational ducted X8 helicopters, and now hexacopters
- Boeing Passenger Air Vehicle - an American octocopter prototype fitted with a pusher propeller and three wings for horizontal flight
- Jetson One - a Swedish-Italian ultralight X8 helicopter, with four coaxial rotor booms fitted to a motorcycle-like cockpit
- Pivotal BlackFly - an American octocopter designed to fully rotate in orientation to transition between vertical and horizontal flight, much like more traditional tail-sitters
- Volocopter designs - a series of German prototype electric multicopters, many such as the 2X & Volocity with 18 rotors, the first electric multicopter in the world to achieve crewed flight.[21][22] The large number of low-cost motors make it economical, quiet and provide redundancy with ability to maintain control with up to four failed motors.[23]
References
edit edit source- ^ Early in helicopter development,"multi-rotor" was used to refer to helicopters with two rotor assemblies Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "HeliQuads (Variable Pitch Multicopters) — Copter documentation". ardupilot.org. Retrieved 2026-02-23. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "AeroQuad - The Open Source Quadcopter". Archived from the original on 2012-01-03. Retrieved 2012-01-05. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "Multicopter Table". multicopter.org. Archived from the original on 6 November 2011. Retrieved 30 June 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "FrontPage - UAVP-NG - The Open Source Next Generation Multicopter". uavp.ch. Retrieved 30 June 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "FrontPage - UAVP-NG - The Open Source Next Generation Multicopter". uavp.ch. Retrieved 30 June 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "DIY Drones". diydrones.com. Retrieved 30 June 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ OpenPilot Archived 2011-05-27 at the Wayback Machine Open source UAV autopilot for multirotors Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "How to Pick The Best Multirotor Frame". My First Drone. Archived from the original on 3 April 2014. Retrieved 30 June 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "Octo Quad". ardupilot.org. Retrieved 30 December 2019. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "ALMA Filmed with Hexacopter". ESO Announcement. Retrieved 6 September 2013. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "Multirotor Frame Configurations". Coptercraft. Retrieved 23 December 2015. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "Hybrid VTOL Fixed Wing UAV - DeltaQuad Autonomous VTOL Drone". unmannedsystemstechnology.com. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "QuadRanger VTOL". Archived from the original on 2018-11-06. Retrieved 2018-04-29. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ Coxworth, Ben (February 19, 2015). "SkyProwler combines a quadcopter and a fixed-wing airplane in one device". New Atlas. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "QuadPlane Overview — Plane documentation". ardupilot.org. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ Xiao, Kun; Meng, Yao; Dai, Xunhua; Zhang, Haotian; Quan, Quan (2021-06-15). "A Lifting Wing Fixed on Multirotor UAVs for Long Flight Ranges". 2021 International Conference on Unmanned Aircraft Systems (ICUAS). IEEE. pp. 1605–1610. arXiv:2006.15579. doi:10.1109/icuas51884.2021.9476859. ISBN 978-1-6654-1535-4. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ Zhang, Haotian; Tan, Shaochang; Song, Ziming; Quan, Quan (June 2022). "Performance Evaluation and Design Method of Lifting-Wing Multicopters". IEEE/ASME Transactions on Mechatronics. 27 (3): 1606–1616. doi:10.1109/tmech.2021.3090667. ISSN 1083-4435. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ Quan, Quan; Wang, Shuai; Gao, Wenhan (March 2025). "Lifting-Wing Quadcopter Modeling and Unified Control". Journal of Guidance, Control, and Dynamics. 48 (3): 689–699. arXiv:2301.00730. Bibcode:2025JGCD...48..689Q. doi:10.2514/1.g008134. ISSN 0731-5090. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ Flight 14 April 1949 p427 Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "German multicopter makes first manned flight". sUAS news. 1 November 2011. Retrieved 3 Nov 2011. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "Volocopter: 18-propeller electric helicopter takes flight". CNN news. 27 November 2013. Retrieved 2 Dec 2013. Wikipedia revision 1364448842, retrieved 2026-11-20
- ^ "New Aircraft Arises from Germany". Sport Aviation: 14. January 2012. Wikipedia revision 1364448842, retrieved 2026-11-20
Text derived from https://en.wikipedia.org/w/index.php?oldid=1364448842 under CC BY-SA 4.0; modifications have been made.